











What Are the Parts of a Drone?
|
|
Time to read 9.12 min
|
|
Time to read 9.12 min
A drone requires a reliable propulsion system to get off the ground and stay airborne. This system consists of three main components that work together to lift the device, determine its direction, and maintain stability in the wind.
The frame acts as the main skeleton, securing internal electronics and supporting the arms. Consumer models typically use high-strength plastics to keep production costs low while staying light enough to meet regulations, like the popular under-250g category. In contrast, professional or heavy-lift drones often rely on carbon fiber. While carbon fiber offers superior rigidity and impact resistance, it significantly increases the price. The frame's physical size determines the maximum propeller length, which dictates how much battery weight or camera gear the drone can carry.
Motors spin the propellers at high speeds to push air downward and generate lift. Most consumer drones feature four brushless motors, which are the industry standard because they operate efficiently, produce minimal heat, and outlast older brushed alternatives.Rotation direction is critical for stability. If all four propellers spun the same way, torque would cause the entire drone to spin out of control. To prevent this, manufacturers install them in specific pairs: two motors rotate clockwise (CW), and the other two rotate counter-clockwise (CCW). This opposing movement neutralizes torque, allowing the drone to hover perfectly still.
The Electronic Speed Controller (ESC) acts as the hardware's power manager. When the drone's main computer calculates how the aircraft needs to move, the ESC translates those digital signals into precise electrical currents for each motor.If a gust of wind hits the drone, the ESC instantly adjusts the RPM (revolutions per minute) of specific motors to compensate and keep the flight level. A high-quality ESC ensures the drone responds smoothly and predictably to joystick inputs, eliminating jerky or delayed aerial movements.
The Flight Controller (FC) is the main circuit board of the drone. It receives your joystick inputs from the remote control and cross-references them with real-time data from the drone's onboard sensors. It calculates exactly how fast each individual motor needs to spin and sends those specific commands to the ESCs in milliseconds. This continuous data processing is what allows the drone to execute your directional movements accurately and hover perfectly in place the moment you let go of the joysticks.
Usually built directly into the flight controller, the Inertial Measurement Unit (IMU) is a dedicated collection of sensors that constantly monitor the aircraft's physical orientation in the sky. It relies on two main sensor groups:
When a gust of wind pushes the drone, the IMU instantly detects the unwanted movement and feeds that data to the flight controller to automatically correct the position.
Most consumer drones use Lithium-Polymer (LiPo) or Lithium-Ion (Li-ion) batteries because they are lightweight and discharge power quickly. When reading battery specifications, two main metrics dictate performance:
While upgrading to a higher-capacity battery increases flight time, it also adds physical weight. This extra mass forces the motors to work harder, which slightly reduces the expected flight time gains. A heavier battery can easily push the total weight of the drone over the 250-gram regulatory threshold.
The Global Positioning System (GPS) module connects to satellites to track the drone's exact coordinates. This allows the drone to hold its position outdoors automatically, even in the wind. More importantly, it enables the Return-to-Home (RTH) safety feature. If the drone loses its connection to the remote control or the battery runs low, the system uses the recorded GPS data to fly back to the exact takeoff point and land automatically.
Since GPS often fails indoors or under dense tree cover, drones rely on vision sensors. Downward sensors read ground textures to keep the drone hovering steadily without satellite signals. Meanwhile, many models also feature forward, backward, or side-facing sensors to detect physical obstacles. If they spot a wall or a tree branch, they signal the flight controller to either brake immediately or route the drone around the object to avoid a crash.
While the camera determines resolution and frame rate, the gimbal physically stabilizes the footage. A mechanical gimbal is a mount equipped with micro-motors that counteract the drone's movements. When the drone tilts forward to fly or shakes in the wind, the gimbal instantly moves the camera in the exact opposite direction. This absorbs vibrations, allowing a 3-axis mechanical gimbal to record perfectly smooth video.
Drones require a reliable communication link between the pilot and the aircraft to transmit flight commands and receive live video.
The remote control's transmitter broadcasts flight commands to the drone's receiver using 2.4 GHz or 5.8 GHz radio frequencies. Many systems automatically switch between these bands during flight to avoid interference from local Wi-Fi networks or cell towers. This ensures the drone responds instantly to joystick inputs without losing the signal.
The video downlink sends the live camera feed directly to the pilot's screen. The specific transmission technology dictates the drone's maximum effective range. Basic models use standard Wi-Fi, which works for short, clear distances but loses signal behind physical obstacles. Premium models use proprietary radio systems to transmit high-definition video over several miles with minimal delay.
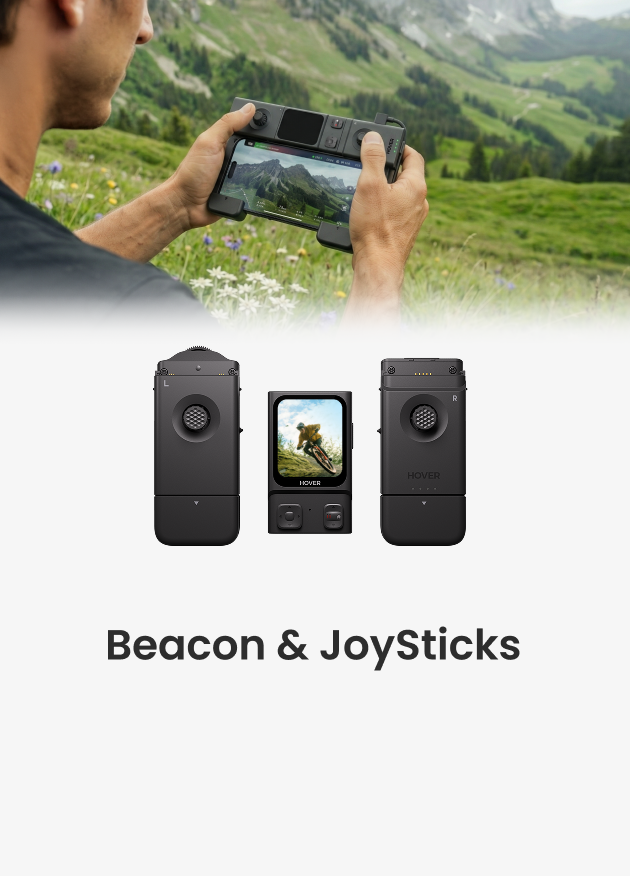
Dedicated remote controllers feature physical joysticks and antennas to maximize transmission range and precision. However, modern flying cameras often eliminate the physical remote entirely to prioritize portability. These compact devices connect directly to a smartphone app via Wi-Fi, placing the live video feed and flight controls on your screen. While an app-only approach limits the maximum flight distance, it creates a significantly lighter and more convenient setup.
The core hardware components can be arranged into various physical configurations depending on the drone's intended use.
Multi-rotors use multiple downward-facing propellers to lift off vertically and hover. Quadcopters feature four rotors and are the standard for consumer photography and flying cameras. Hexacopters use six rotors to lift heavier cinematic gear. These extra motors also provide mechanical redundancy, allowing the drone to land safely even if one motor fails mid-air.
Fixed-wing drones rely on aerodynamic wings and a single forward-facing motor. They cannot hover and require a runway or a hand-launch to take off. However, generating lift with wings requires significantly less battery power. This efficiency makes them ideal for long-distance agricultural mapping and surveying large plots of land.
While technically multi-rotors, First-Person View (FPV) drones use stripped-down frames and oversized motors to maximize raw speed and agility. They skip automated safety features like GPS return-to-home to save weight. The pilot wears video goggles that display the live camera feed with near-zero latency, making this setup standard for drone racing and fast cinematic tracking shots.
Latest Articles

Most drones handle the sky beautifully, but they become fragile the second they encounter a lake or a heavy splash of sea spray. If you want to know what kind...
Most drones handle the sky beautifully, but they become fragile the second they encounter a lake or a heavy splash of sea spray. If you want to know what kind...

Ever searched for a drone that can automatically follow your kayaking trips? If you ask around, most people will tell you it's impossible without a skilled pilot on the beach...
Ever searched for a drone that can automatically follow your kayaking trips? If you ask around, most people will tell you it's impossible without a skilled pilot on the beach...

The HOVERAir AQUA has been designed with the water fully in mind. In addition to the technical challenges of creating a fully waterproof drone under 250g, we also carefully considered...
The HOVERAir AQUA has been designed with the water fully in mind. In addition to the technical challenges of creating a fully waterproof drone under 250g, we also carefully considered...

HOVERAir VERSA combines handheld filming and self-flying capture in one compact device. This guide covers everything you need to get started, from setting up your VERSA to capturing your first...
HOVERAir VERSA combines handheld filming and self-flying capture in one compact device. This guide covers everything you need to get started, from setting up your VERSA to capturing your first...

The standard advice for filming a solo water session is always the same: skip the drone and buy a 360 camera on a long stick. Until recently, that was the...
The standard advice for filming a solo water session is always the same: skip the drone and buy a 360 camera on a long stick. Until recently, that was the...

The Beacon and JoySticks serve as HOVERAir's all-new remote control solution, fully compatible across our entire lineup—from the X1 and X1 PRO/PROMAX to the AQUA. Acting as a unique tri-state...
The Beacon and JoySticks serve as HOVERAir's all-new remote control solution, fully compatible across our entire lineup—from the X1 and X1 PRO/PROMAX to the AQUA. Acting as a unique tri-state...


